
散焦模糊去除滤波
在本教程中,你将学到:
- 什么是图像退化模型(degradation image model);
- 什么是散焦图像的点扩散函数(PSF,point spread function);
- 如何恢复一幅模糊图像;
- 什么是维纳滤波器(Wiener filter)。
什么是图像退化模型?
Section titled “什么是图像退化模型?”下面是频域表示下的图像退化数学模型:
其中 是模糊(退化)图像的频谱, 是原始真实(未退化)图像的频谱, 是点扩散函数(PSF)的频率响应, 是加性噪声的频谱。
圆形 PSF 是对散焦失真的一种良好近似。这样的 PSF 只由一个参数——半径 指定。本工作使用的就是圆形 PSF。
如何恢复一幅模糊图像?
Section titled “如何恢复一幅模糊图像?”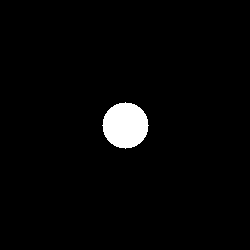
恢复(去模糊)的目标是获得原始图像的一个估计。频域中的恢复公式为:
其中 是原始图像 的估计的频谱, 是恢复滤波器,例如维纳滤波器。
什么是维纳滤波器?
Section titled “什么是维纳滤波器?”维纳滤波器是恢复模糊图像的一种方法。假设 PSF 是实对称信号,且原始真实图像与噪声的功率谱均未知,那么简化后的维纳公式为:
其中 是信噪比(signal-to-noise ratio)。
因此,为了用维纳滤波器恢复一幅散焦图像,需要知道圆形 PSF 的 和 。
你可以在 OpenCV 源代码库的 samples/cpp/tutorial_code/ImgProc/out_of_focus_deblur_filter/out_of_focus_deblur_filter.cpp 中找到源代码。
/*** @brief You will learn how to recover an out-of-focus image by Wiener filter* @author Karpushin Vladislav, karpushin@ngs.ru, https://github.com/VladKarpushin*/#include <iostream>#include "opencv2/highgui.hpp"#include "opencv2/imgproc.hpp"#include "opencv2/imgcodecs.hpp"
using namespace cv;using namespace std;
void help();void calcPSF(Mat& outputImg, Size filterSize, int R);void fftshift(const Mat& inputImg, Mat& outputImg);void filter2DFreq(const Mat& inputImg, Mat& outputImg, const Mat& H);void calcWnrFilter(const Mat& input_h_PSF, Mat& output_G, double nsr);
const String keys ="{help h usage ? |             | print this message   }""{image          |original.jpg | input image name     }""{R              |5           | radius               }""{SNR            |100         | signal to noise ratio}";
int main(int argc, char *argv[]){    help();    CommandLineParser parser(argc, argv, keys);    if (parser.has("help"))    {        parser.printMessage();        return 0;    }
    int R = parser.get<int>("R");    int snr = parser.get<int>("SNR");    string strInFileName = parser.get<String>("image");    samples::addSamplesDataSearchSubDirectory("doc/tutorials/imgproc/out_of_focus_deblur_filter/images");
    if (!parser.check())    {        parser.printErrors();        return 0;    }
    Mat imgIn;    imgIn = imread(samples::findFile( strInFileName ), IMREAD_GRAYSCALE);    if (imgIn.empty()) //check whether the image is loaded or not    {        cout << "ERROR : Image cannot be loaded..!!" << endl;        return -1;    }
    Mat imgOut;
    // it needs to process even image only    Rect roi = Rect(0, 0, imgIn.cols & -2, imgIn.rows & -2);
    //Hw calculation (start)    Mat Hw, h;    calcPSF(h, roi.size(), R);    calcWnrFilter(h, Hw, 1.0 / double(snr));    //Hw calculation (stop)
    // filtering (start)    filter2DFreq(imgIn(roi), imgOut, Hw);    // filtering (stop)
    imgOut.convertTo(imgOut, CV_8U);    normalize(imgOut, imgOut, 0, 255, NORM_MINMAX);    imshow("Original", imgIn);    imshow("Debluring", imgOut);    imwrite("result.jpg", imgOut);    waitKey(0);    return 0;}
void help(){    cout << "2018-07-12" << endl;    cout << "DeBlur_v8" << endl;    cout << "You will learn how to recover an out-of-focus image by Wiener filter" << endl;}
void calcPSF(Mat& outputImg, Size filterSize, int R){    Mat h(filterSize, CV_32F, Scalar(0));    Point point(filterSize.width / 2, filterSize.height / 2);    circle(h, point, R, 255, -1, 8);    Scalar summa = sum(h);    outputImg = h / summa[0];}
void fftshift(const Mat& inputImg, Mat& outputImg){    outputImg = inputImg.clone();    int cx = outputImg.cols / 2;    int cy = outputImg.rows / 2;    Mat q0(outputImg, Rect(0, 0, cx, cy));    Mat q1(outputImg, Rect(cx, 0, cx, cy));    Mat q2(outputImg, Rect(0, cy, cx, cy));    Mat q3(outputImg, Rect(cx, cy, cx, cy));    Mat tmp;    q0.copyTo(tmp);    q3.copyTo(q0);    tmp.copyTo(q3);    q1.copyTo(tmp);    q2.copyTo(q1);    tmp.copyTo(q2);}
void filter2DFreq(const Mat& inputImg, Mat& outputImg, const Mat& H){    Mat planes[2] = { Mat_<float>(inputImg.clone()), Mat::zeros(inputImg.size(), CV_32F) };    Mat complexI;    merge(planes, 2, complexI);    dft(complexI, complexI, DFT_SCALE);
    Mat planesH[2] = { Mat_<float>(H.clone()), Mat::zeros(H.size(), CV_32F) };    Mat complexH;    merge(planesH, 2, complexH);    Mat complexIH;    mulSpectrums(complexI, complexH, complexIH, 0);
    idft(complexIH, complexIH);    split(complexIH, planes);    outputImg = planes[0];}
void calcWnrFilter(const Mat& input_h_PSF, Mat& output_G, double nsr){ Mat h_PSF_shifted; fftshift(input_h_PSF, h_PSF_shifted); Mat planes[2] = { Mat_<float>(h_PSF_shifted.clone()), Mat::zeros(h_PSF_shifted.size(), CV_32F) }; Mat complexI; merge(planes, 2, complexI); dft(complexI, complexI); split(complexI, planes); Mat denom; pow(abs(planes[0]), 2, denom); denom += nsr; divide(planes[0], denom, output_G);}一个散焦图像恢复算法由 PSF 生成、维纳滤波器生成以及在频域中对模糊图像进行滤波三部分组成:
// it needs to process even image onlyRect roi = Rect(0, 0, imgIn.cols & -2, imgIn.rows & -2);
//Hw calculation (start)Mat Hw, h;calcPSF(h, roi.size(), R);calcWnrFilter(h, Hw, 1.0 / double(snr));//Hw calculation (stop)
// filtering (start)filter2DFreq(imgIn(roi), imgOut, Hw);// filtering (stop)
函数 calcPSF() 根据输入参数半径 生成圆形 PSF:
void calcPSF(Mat& outputImg, Size filterSize, int R){ Mat h(filterSize, CV_32F, Scalar(0)); Point point(filterSize.width / 2, filterSize.height / 2); circle(h, point, R, 255, -1, 8); Scalar summa = sum(h); outputImg = h / summa[0];}函数 calcWnrFilter() 按照上面描述的公式合成简化的维纳滤波器 :
void calcWnrFilter(const Mat& input_h_PSF, Mat& output_G, double nsr){ Mat h_PSF_shifted; fftshift(input_h_PSF, h_PSF_shifted); Mat planes[2] = { Mat_<float>(h_PSF_shifted.clone()), Mat::zeros(h_PSF_shifted.size(), CV_32F) }; Mat complexI; merge(planes, 2, complexI); dft(complexI, complexI); split(complexI, planes); Mat denom; pow(abs(planes[0]), 2, denom); denom += nsr; divide(planes[0], denom, output_G);}函数 fftshift() 对 PSF 进行重新排列。这段代码是从离散傅里叶变换(Discrete Fourier Transform)教程中直接复制过来的:
void fftshift(const Mat& inputImg, Mat& outputImg){ outputImg = inputImg.clone(); int cx = outputImg.cols / 2; int cy = outputImg.rows / 2; Mat q0(outputImg, Rect(0, 0, cx, cy)); Mat q1(outputImg, Rect(cx, 0, cx, cy)); Mat q2(outputImg, Rect(0, cy, cx, cy)); Mat q3(outputImg, Rect(cx, cy, cx, cy)); Mat tmp; q0.copyTo(tmp); q3.copyTo(q0); tmp.copyTo(q3); q1.copyTo(tmp); q2.copyTo(q1); tmp.copyTo(q2);}函数 filter2DFreq() 在频域中对模糊图像进行滤波:
void filter2DFreq(const Mat& inputImg, Mat& outputImg, const Mat& H){    Mat planes[2] = { Mat_<float>(inputImg.clone()), Mat::zeros(inputImg.size(), CV_32F) };    Mat complexI;    merge(planes, 2, complexI);    dft(complexI, complexI, DFT_SCALE);
    Mat planesH[2] = { Mat_<float>(H.clone()), Mat::zeros(H.size(), CV_32F) };    Mat complexH;    merge(planesH, 2, complexH);    Mat complexIH;    mulSpectrums(complexI, complexH, complexIH, 0);
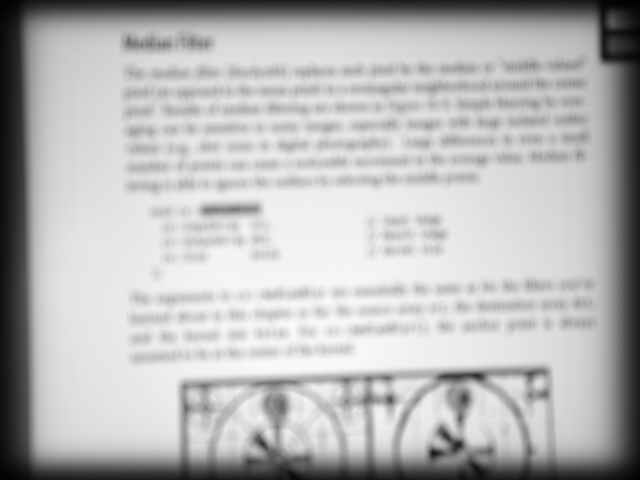
idft(complexIH, complexIH); split(complexIH, planes); outputImg = planes[0];}下图是一幅真实的散焦图像:
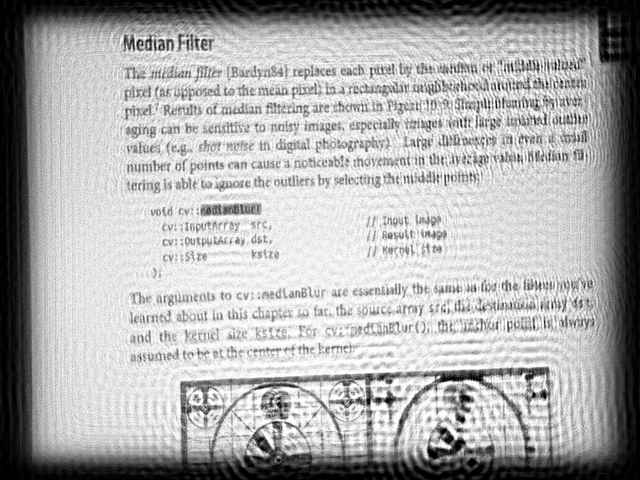
下面的结果是使用参数 = 53 和 = 5200 计算得到的:
这里使用了维纳滤波器, 和 的值是手动选择的,以获得尽可能好的视觉效果。可以看到,结果并不完美,但它让我们大致看出了图像的内容。尽管有些吃力,文字已经可以辨认了。
你还可以在 YouTube 上找到一个快速视频演示。
- Image Deblurring in Matlab — Matlab 中的图像去模糊
- SmartDeblur — SmartDeblur 网站