
ISS 关键点检测
本教程展示如何检测三维形状的 ISS 关键点(keypoints)。其实现基于 Yu Zhong 在 2009 年论文《Intrinsic Shape Signatures: A Shape Descriptor for 3D Object Recognition》中提出的关键点检测模块。
ISS 关键点
Section titled “ISS 关键点”ISS 显著性度量(saliency measure)基于点 支撑域内各点的散布矩阵(scatter matrix) 的特征值分解(Eigenvalue Decomposition, EVD),即:
给定 ,其特征值按从大到小的顺序记为 、、。在剪枝(pruning)阶段,会保留相邻两个特征值之比低于某阈值的点:
这样做的理由是:避免在沿各主方向具有相似展布的点上检测关键点——在这些点上无法建立可重复的规范参考系(canonical reference frame),因此随后的描述阶段很难取得好的效果。在剩余的点中,显著性由最小特征值的大小决定:
从而只保留沿每个主方向都有较大变化的点。检测之后,如果某点在给定邻域内具有最大的显著性值,则被视为关键点。
ISS 关键点检测示例
Section titled “ISS 关键点检测示例”# Compute ISS Keypoints on ArmadilloMesharmadillo = o3d.data.ArmadilloMesh()mesh = o3d.io.read_triangle_mesh(armadillo.path)mesh.compute_vertex_normals()
pcd = o3d.geometry.PointCloud()pcd.points = mesh.vertices
tic = time.time()keypoints = o3d.geometry.keypoint.compute_iss_keypoints(pcd)toc = 1000 * (time.time() - tic)print("ISS Computation took {:.0f} [ms]".format(toc))
mesh.compute_vertex_normals()mesh.paint_uniform_color([0.5, 0.5, 0.5])keypoints.paint_uniform_color([1.0, 0.75, 0.0])o3d.visualization.draw_geometries([keypoints, mesh], front=[0, 0, -1.0])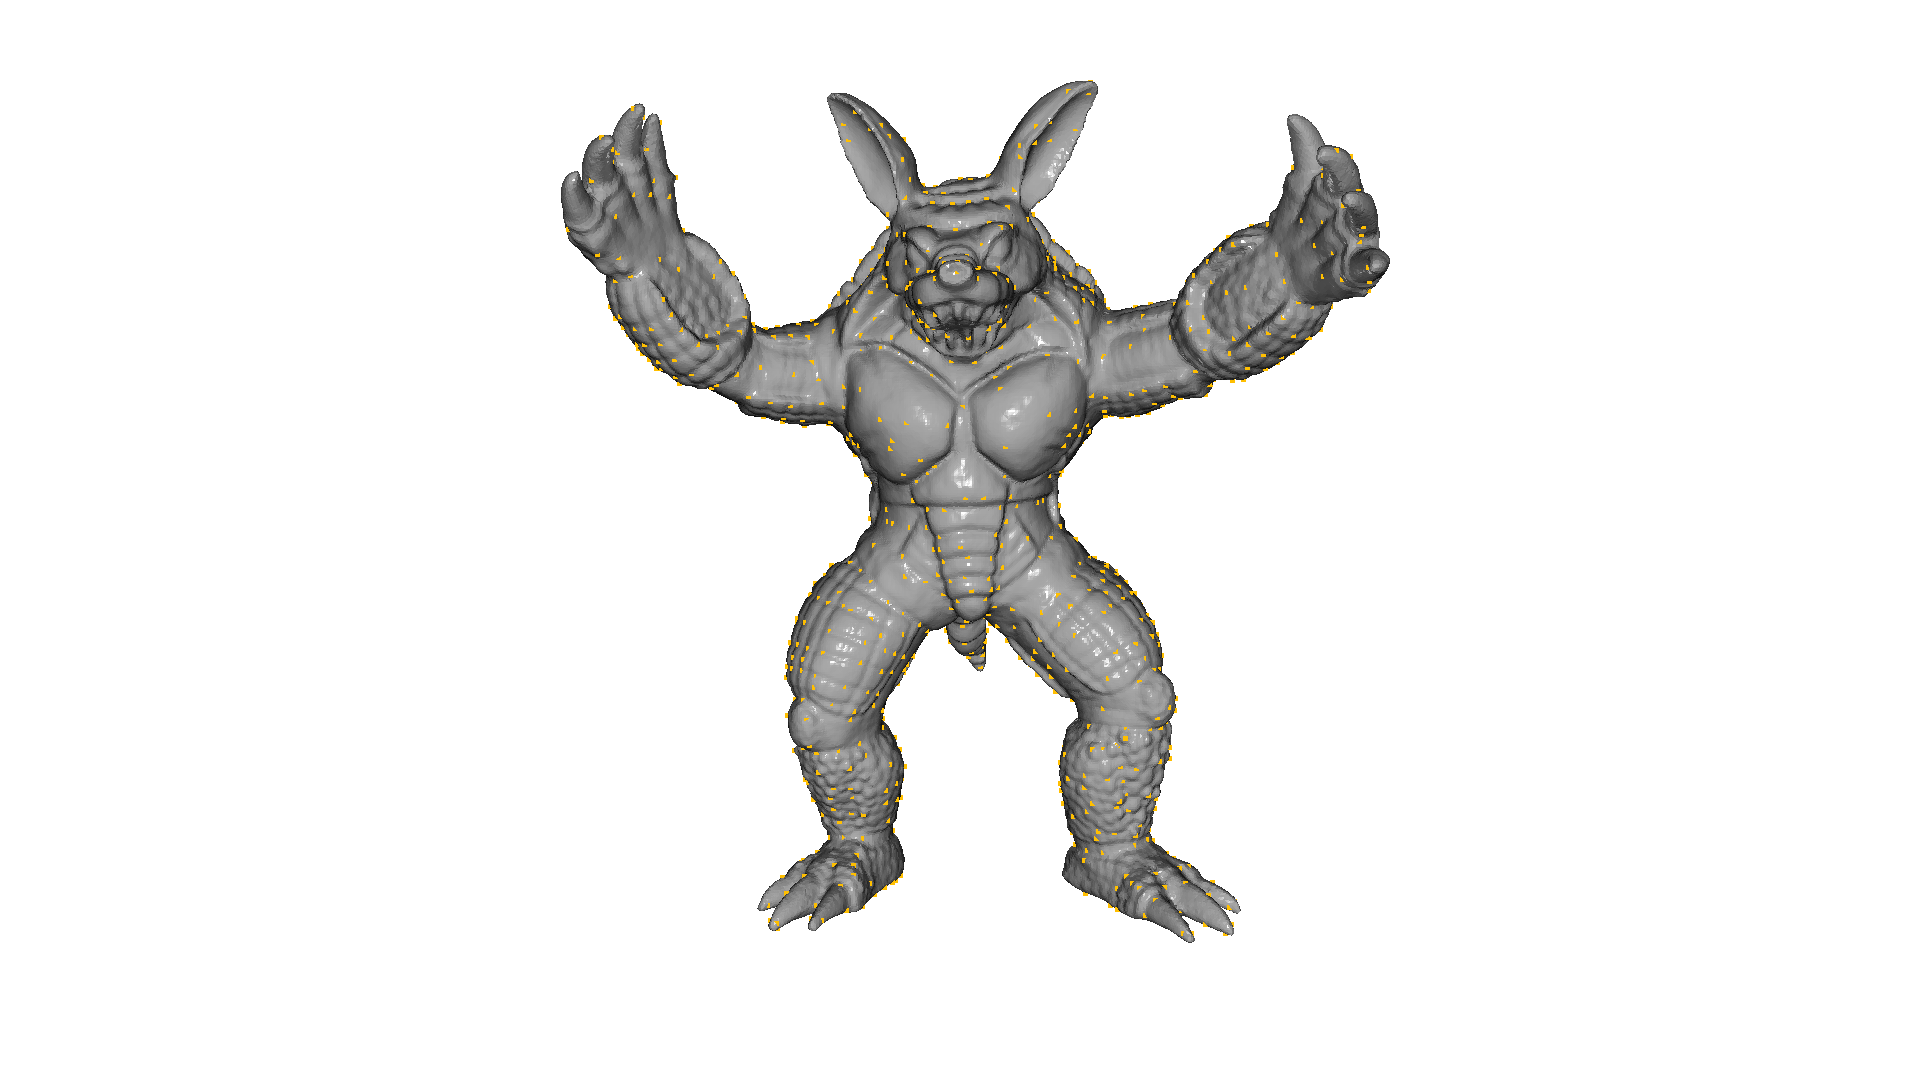
输出:
ISS Computation took 666 [ms]# This function is only used to make the keypoints look better on the renderingdef keypoints_to_spheres(keypoints): spheres = o3d.geometry.TriangleMesh() for keypoint in keypoints.points: sphere = o3d.geometry.TriangleMesh.create_sphere(radius=0.001) sphere.translate(keypoint) spheres += sphere spheres.paint_uniform_color([1.0, 0.75, 0.0]) return spheres# Compute ISS Keypoints on Standford BunnyMesh, changing the default parametersbunny = o3d.data.BunnyMesh()mesh = o3d.io.read_triangle_mesh(bunny.path)mesh.compute_vertex_normals()
pcd = o3d.geometry.PointCloud()pcd.points = mesh.vertices
tic = time.time()keypoints = o3d.geometry.keypoint.compute_iss_keypoints(pcd, salient_radius=0.005, non_max_radius=0.005, gamma_21=0.5, gamma_32=0.5)toc = 1000 * (time.time() - tic)print("ISS Computation took {:.0f} [ms]".format(toc))
mesh.compute_vertex_normals()mesh.paint_uniform_color([0.5, 0.5, 0.5])o3d.visualization.draw_geometries([keypoints_to_spheres(keypoints), mesh])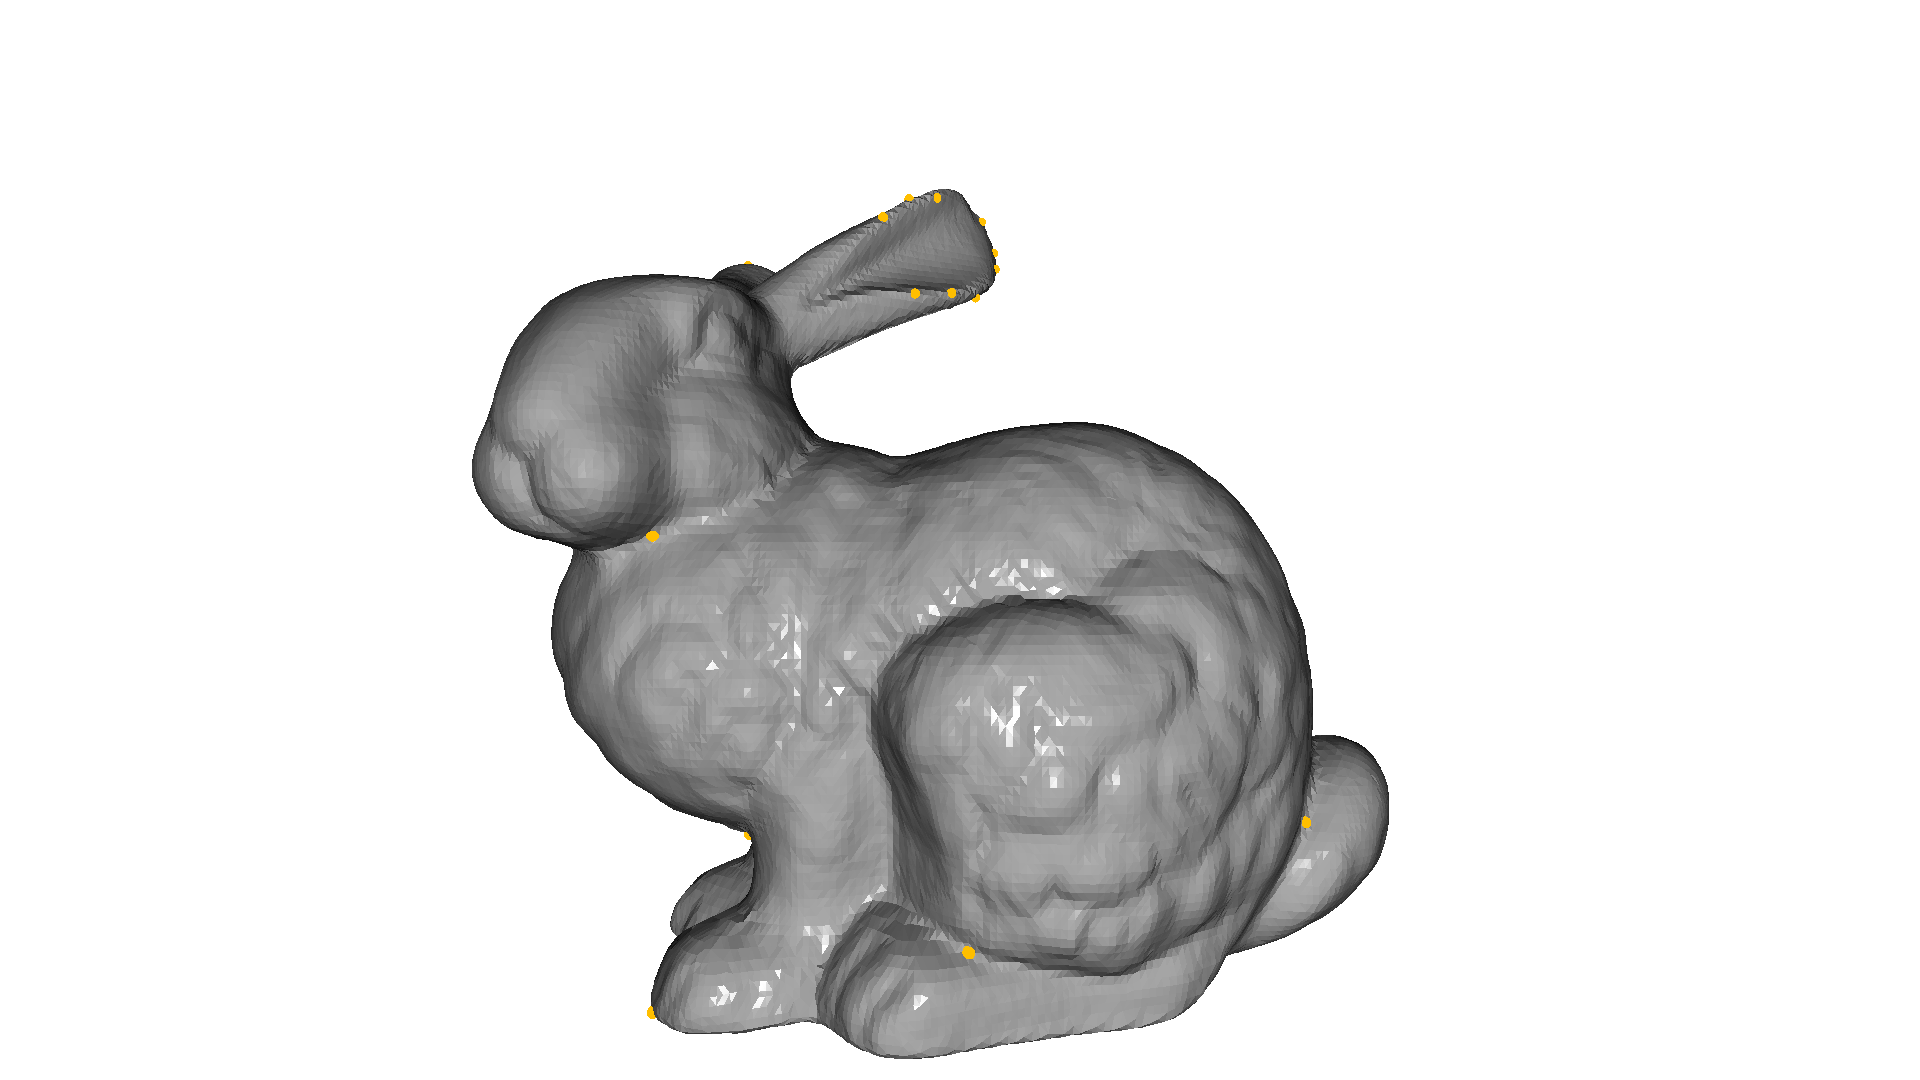
输出:
ISS Computation took 57 [ms]