
TF2 广播器(C++)
目标: 学习如何将机器人的状态广播到 tf2。
教程级别: 中级
预计时间: 15 分钟
在接下来的两个教程中,我们将编写代码来重现 tf2 简介教程中的演示。后续教程将在此基础上引入更高级的 tf2 功能来扩展该演示,包括变换查询中的超时处理和时间旅行。
本教程假设你已经具备 ROS 2 基础知识,并且完成了 tf2 简介教程和 tf2 静态广播器教程(C++)。我们将复用上一个教程中的 learning_tf2_cpp 功能包。
在之前的教程中,你已经学习了如何创建工作空间和功能包。
1 编写广播器节点
Section titled “1 编写广播器节点”首先创建源文件。进入上一个教程中创建的 learning_tf2_cpp 功能包,在 src 目录中输入以下命令,下载示例广播器代码:
Linux/macOS:
wget https://raw.githubusercontent.com/ros/geometry_tutorials/{DISTRO}/turtle_tf2_cpp/src/turtle_tf2_broadcaster.cppWindows:
在 Windows 命令行提示符中:
curl -sk https://raw.githubusercontent.com/ros/geometry_tutorials/{DISTRO}/turtle_tf2_cpp/src/turtle_tf2_broadcaster.cpp -o turtle_tf2_broadcaster.cpp或者在 PowerShell 中:
curl https://raw.githubusercontent.com/ros/geometry_tutorials/{DISTRO}/turtle_tf2_cpp/src/turtle_tf2_broadcaster.cpp -o turtle_tf2_broadcaster.cpp使用你喜欢的文本编辑器打开该文件。
#include <functional>#include <memory>#include <sstream>#include <string>
#include "geometry_msgs/msg/transform_stamped.hpp"#include "rclcpp/rclcpp.hpp"#include "tf2/LinearMath/Quaternion.hpp"#include "tf2_ros/transform_broadcaster.h"#include "turtlesim_msgs/msg/pose.hpp"
class FramePublisher : public rclcpp::Node{public:  FramePublisher()  : Node("turtle_tf2_frame_publisher")  {    // Declare and acquire `turtlename` parameter    turtlename_ = this->declare_parameter<std::string>("turtlename", "turtle");
    // Initialize the transform broadcaster    tf_broadcaster_ =      std::make_unique<tf2_ros::TransformBroadcaster>(*this);
    // Subscribe to a turtle{1}{2}/pose topic and call handle_turtle_pose    // callback function on each message    std::ostringstream stream;    stream << "/" << turtlename_.c_str() << "/pose";    std::string topic_name = stream.str();
    auto handle_turtle_pose = [this](const std::shared_ptr<const turtlesim_msgs::msg::Pose> msg){        geometry_msgs::msg::TransformStamped t;
        // Read message content and assign it to        // corresponding tf variables        t.header.stamp = this->get_clock()->now();        t.header.frame_id = "world";        t.child_frame_id = turtlename_.c_str();
        // Turtle only exists in 2D, thus we get x and y translation        // coordinates from the message and set the z coordinate to 0        t.transform.translation.x = msg->x;        t.transform.translation.y = msg->y;        t.transform.translation.z = 0.0;
        // For the same reason, turtle can only rotate around one axis        // and this why we set rotation in x and y to 0 and obtain        // rotation in z axis from the message        tf2::Quaternion q;        q.setRPY(0, 0, msg->theta);        t.transform.rotation.x = q.x();        t.transform.rotation.y = q.y();        t.transform.rotation.z = q.z();        t.transform.rotation.w = q.w();
        // Send the transformation        tf_broadcaster_->sendTransform(t);    };    subscription_ = this->create_subscription<turtlesim_msgs::msg::Pose>(      topic_name, 10,      handle_turtle_pose);  }
private:  rclcpp::Subscription<turtlesim_msgs::msg::Pose>::SharedPtr subscription_;  std::unique_ptr<tf2_ros::TransformBroadcaster> tf_broadcaster_;  std::string turtlename_;};
int main(int argc, char * argv[]){  rclcpp::init(argc, argv);  rclcpp::spin(std::make_shared<FramePublisher>());  rclcpp::shutdown();  return 0;}
1.1 代码解析
Section titled “1.1 代码解析”下面来看看与将乌龟位姿发布到 tf2 相关的代码。
首先,定义并获取参数 turtlename,用于指定乌龟名称,例如 turtle1 或 turtle2。
turtlename_ = this->declare_parameter<std::string>("turtlename", "turtle");然后,节点订阅话题 turtleX/pose,每收到一条消息就调用 handle_turtle_pose 回调函数。
subscription_ = this->create_subscription<turtlesim_msgs::msg::Pose>( topic_name, 10, handle_turtle_pose);接下来创建一个 TransformStamped 对象,并设置相应的元数据。
-
首先为要发布的变换设置时间戳,通过调用
this->get_clock()->now()获取当前时间,返回的是该节点使用的当前时间。 -
然后设置所创建变换的父坐标系名称,这里是
world。 -
最后设置子坐标系名称,即乌龟本身的名称。
乌龟位姿消息的回调函数负责广播该乌龟的平移和旋转,将其作为从 world 坐标系到 turtleX 坐标系的变换发布出去。
geometry_msgs::msg::TransformStamped t;
// Read message content and assign it to// corresponding tf variablest.header.stamp = this->get_clock()->now();t.header.frame_id = "world";t.child_frame_id = turtlename_.c_str();
这里将乌龟的位姿信息填入 3D 变换结构中。
// Turtle only exists in 2D, thus we get x and y translation// coordinates from the message and set the z coordinate to 0t.transform.translation.x = msg->x;t.transform.translation.y = msg->y;t.transform.translation.z = 0.0;
// For the same reason, turtle can only rotate around one axis// and this why we set rotation in x and y to 0 and obtain// rotation in z axis from the messagetf2::Quaternion q;q.setRPY(0, 0, msg->theta);t.transform.rotation.x = q.x();t.transform.rotation.y = q.y();t.transform.rotation.z = q.z();t.transform.rotation.w = q.w();
最后,将构造好的变换传递给 TransformBroadcaster 的 sendTransform 方法,由它负责广播。
// Send the transformationtf_broadcaster_->sendTransform(t);1.2 CMakeLists.txt
Section titled “1.2 CMakeLists.txt”返回上一级到 learning_tf2_cpp 目录,该目录下存放着 CMakeLists.txt 和 package.xml 文件。
打开 CMakeLists.txt,添加可执行文件并命名为 turtle_tf2_broadcaster,稍后你可以通过 ros2 run 来运行它。
find_package(turtlesim_msgs REQUIRED)add_executable(turtle_tf2_broadcaster src/turtle_tf2_broadcaster.cpp)target_link_libraries( turtle_tf2_broadcaster PUBLIC geometry_msgs::geometry_msgs rclcpp::rclcpp tf2::tf2 tf2_ros::tf2_ros turtlesim_msgs::turtlesim_msgs)最后,添加 install(TARGETS…) 部分,以便 ros2 run 能找到你的可执行文件:
install(TARGETS turtle_tf2_broadcaster DESTINATION lib/${PROJECT_NAME})2 编写 launch 文件
Section titled “2 编写 launch 文件”接下来为这个演示创建一个 launch 文件。在 src/learning_tf2_cpp 目录下创建一个 launch 文件夹。用文本编辑器在其中创建一个名为 turtle_tf2_demo_launch 的新文件,扩展名为 .py、.xml 或 .yaml,添加以下内容:
XML:
<?xml version="1.0" encoding="UTF-8"?><launch> <node pkg="turtlesim" exec="turtlesim_node" name="sim" /> <node pkg="learning_tf2_cpp" exec="turtle_tf2_broadcaster" name="broadcaster1"> <param name="turtlename" value="turtle1" /> </node></launch>YAML:
%YAML 1.2---launch: - node: pkg: "turtlesim" exec: "turtlesim_node" name: "sim" - node: pkg: "learning_tf2_cpp" exec: "turtle_tf2_broadcaster" name: "broadcaster1" param: - name: "turtlename" value: "turtle1"Python:
from launch import LaunchDescriptionfrom launch_ros.actions import Node

def generate_launch_description():    return LaunchDescription([        Node(            package='turtlesim',            executable='turtlesim_node',            name='sim'        ),        Node(            package='learning_tf2_cpp',            executable='turtle_tf2_broadcaster',            name='broadcaster1',            parameters=[                {'turtlename': 'turtle1'}            ]        ),    ])
2.1 代码解析
Section titled “2.1 代码解析”下面来分析 launch 文件的结构。每种格式都有各自的写法:
XML:
XML launch 文件以 XML 声明和根元素 <launch> 开头。
<?xml version="1.0" encoding="UTF-8"?><launch>YAML:
YAML launch 文件以 YAML 版本声明和 launch: 键开头。
%YAML 1.2---launch:Python:
在 Python launch 文件中,首先从 launch 和 launch_ros 包导入所需模块。需要注意的是,launch 是一个通用的启动框架(并非 ROS 2 专用),而 launch_ros 包含了 ROS 2 特有的功能,比如这里导入的节点。
from launch import LaunchDescriptionfrom launch_ros.actions import Node接下来启动 turtlesim 仿真节点,并使用 turtle_tf2_broadcaster 节点将 turtle1 的状态广播到 tf2。
XML:
<node pkg="turtlesim" exec="turtlesim_node" name="sim" /> <node pkg="learning_tf2_cpp" exec="turtle_tf2_broadcaster" name="broadcaster1"> <param name="turtlename" value="turtle1" /> </node>YAML:
- node: pkg: "turtlesim" exec: "turtlesim_node" name: "sim" - node: pkg: "learning_tf2_cpp" exec: "turtle_tf2_broadcaster" name: "broadcaster1" param: - name: "turtlename" value: "turtle1"Python:
return LaunchDescription([ Node( package='turtlesim', executable='turtlesim_node', name='sim' ), Node( package='learning_tf2_cpp', executable='turtle_tf2_broadcaster', name='broadcaster1', parameters=[ {'turtlename': 'turtle1'} ] ), ])2.2 添加依赖
Section titled “2.2 添加依赖”返回上一级到 learning_tf2_cpp 目录,该目录下存放着 CMakeLists.txt 和 package.xml 文件。
用文本编辑器打开 package.xml,添加与 launch 文件导入语句对应的以下依赖:
<exec_depend>launch</exec_depend><exec_depend>launch_ros</exec_depend>这样声明了运行时所需的 launch 和 launch_ros 依赖。
请确保保存文件。
2.3 CMakeLists.txt
Section titled “2.3 CMakeLists.txt”重新打开 CMakeLists.txt,添加以下内容以便安装 launch/ 文件夹中的 launch 文件:
install(DIRECTORY launch DESTINATION share/${PROJECT_NAME})你可以在创建 launch 文件教程中了解更多相关信息。
在工作空间根目录运行 rosdep 检查缺失的依赖。
Linux:
rosdep install -i --from-path src --rosdistro {DISTRO} -ymacOS:
rosdep 仅在 Linux 上可用,你需要自行安装 geometry_msgs 和 turtlesim 依赖。
Windows:
rosdep 仅在 Linux 上可用,你需要自行安装 geometry_msgs 和 turtlesim 依赖。
仍在工作空间根目录下构建功能包:
Linux/macOS:
colcon build --packages-select learning_tf2_cppWindows:
colcon build --merge-install --packages-select learning_tf2_cpp打开一个新终端,导航到工作空间根目录,并 source 环境配置文件:
Linux/macOS:
. install/setup.bashWindows:
在 Windows 命令行提示符中:
call install\setup.bat或者在 PowerShell 中:
.\install\setup.ps1现在运行 launch 文件,它会启动 turtlesim 仿真节点和 turtle_tf2_broadcaster 节点:
XML:
ros2 launch learning_tf2_cpp turtle_tf2_demo_launch.xmlYAML:
ros2 launch learning_tf2_cpp turtle_tf2_demo_launch.yamlPython:
ros2 launch learning_tf2_cpp turtle_tf2_demo_launch.py在第二个终端窗口中输入以下命令:
ros2 run turtlesim turtle_teleop_key你会看到 turtlesim 仿真已启动,其中有一只可以用键盘控制的乌龟。
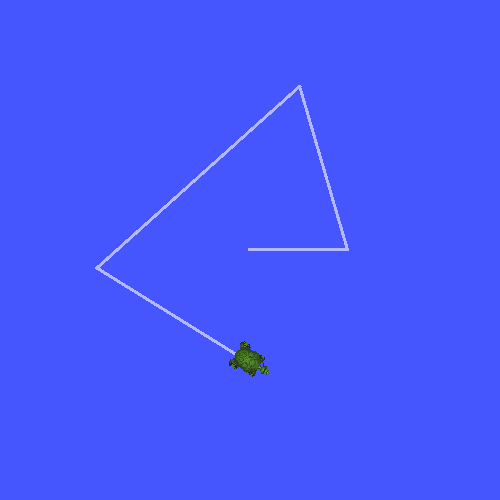
现在,用 tf2_echo 工具检查乌龟位姿是否确实被广播到了 tf2:
ros2 run tf2_ros tf2_echo world turtle1这会显示第一只乌龟的位姿。用方向键驱动乌龟移动(确保当前活动窗口是 turtle_teleop_key 所在的终端,而不是仿真器窗口)。控制台输出类似如下:
At time 1625137663.912474878- Translation: [5.276, 7.930, 0.000]- Rotation: in Quaternion [0.000, 0.000, 0.934, -0.357]At time 1625137664.950813527- Translation: [3.750, 6.563, 0.000]- Rotation: in Quaternion [0.000, 0.000, 0.934, -0.357]At time 1625137665.906280726- Translation: [2.320, 5.282, 0.000]- Rotation: in Quaternion [0.000, 0.000, 0.934, -0.357]At time 1625137666.850775673- Translation: [2.153, 5.133, 0.000]- Rotation: in Quaternion [0.000, 0.000, -0.365, 0.931]如果你对 world 和 turtle2 之间的变换运行 tf2_echo,此时看不到任何输出,因为第二只乌龟尚不存在。不过当我们在下一个教程中添加第二只乌龟后,turtle2 的位姿就会被广播到 tf2。
在本教程中,你学习了如何将机器人的位姿(即乌龟的位置和朝向)广播到 tf2,以及如何使用 tf2_echo 工具进行验证。要实际使用广播到 tf2 的变换,请继续学习下一篇关于创建 tf2 监听器的教程。